If you’ve ever spent time in a machine shop, a packaging line, or an automated assembly plant, you’ve probably noticed that not all linear motion systems are created equal. Some move heavy loads slowly and steadily, others zip across workspaces at breakneck speed with minimal vibration, and the best of them do both without wearing out prematurely. As a supplier of ball screw linear modules, I get asked this question all the time: “What exactly is the speed-torque characteristic of these modules, and why does it matter for my application?” Ball Screw Linear Modules

It’s not just a random technical spec — this characteristic is the backbone of how a ball screw linear module performs, and getting it wrong can lead to everything from lost production time and costly repairs to parts that never meet their design goals. Let me break this down in plain terms, no overly dense jargon, and explain how this fundamental trait shapes every decision we make as suppliers, and every choice you make when picking the right module for your work.
First, let’s start with the basics: a ball screw linear module is a self-contained unit that uses a threaded screw with recirculating ball bearings to convert rotary motion (from a motor) into precise linear motion. Unlike lead screws, which slide along the screw’s threads, ball bearings roll between the screw and the nut, reducing friction drastically. That efficiency is what makes ball screw modules so popular, but it’s also what defines their speed-torque balance.
Torque, simply put, is rotational force — what’s needed to turn the screw. Speed here refers to linear speed, or how far the module’s carriage moves per unit of time, which ties directly to how fast the motor spins the screw. The speed-torque characteristic of a ball screw linear module is the relationship between these two variables: as you increase the speed, how much torque can the module deliver, and vice versa. This isn’t a linear line, though — it’s a curve, and that curve is shaped by several key factors.
Let’s talk about load first, because this is where most users go wrong. If you’re moving a light load, you can spin the screw much faster without needing a lot of torque. Think of sliding a small plastic block across a table with a pencil: twist the pencil fast, and the block moves quickly, no effort needed. But add a heavy metal block, or accelerate the load suddenly, and you need way more force to turn that pencil. For ball screw modules, that means when you’re moving a 50kg payload at 1m/s, you need less torque than when you’re moving the same 50kg load and trying to accelerate from 0 to 1m/s in 0.1 seconds. Acceleration is a big part of this too — higher acceleration demands more torque, even at moderate speeds.
Another critical factor is the screw’s lead. The lead is the distance the nut moves in one full rotation of the screw. A higher lead (say, 20mm per rotation) means the nut moves farther per turn, which lets you get higher linear speed for the same motor RPM. But that higher lead comes with a tradeoff: to generate the same linear force at a higher lead, you need more torque. It’s like using a low vs. high gear on a bike: a high gear lets you go faster, but you have to push harder on the pedals (more torque) to maintain speed. A lower lead (5mm per rotation) gives you more force for the same torque, but lower maximum speed. That’s why when a customer comes to us saying “I need a module that moves 100kg at 2m/s,” our first question is “What’s your maximum load and how much force do you need to move it?” We have to match the screw lead, motor size, and module design to hit both speed and torque targets without overloading the system.
Then there’s the matter of the ball screw’s size and quality. A larger diameter screw can handle more torque, so it can deliver higher forces at lower speeds, and it’s more rigid, which reduces deflection when moving heavy loads. Smaller screws spin faster, so they deliver higher maximum linear speeds, but they can’t handle as much torque. As a supplier, we test every module we build to map this curve — we don’t just guess. We run dynamic load tests, measure how much heat the system generates at different speeds, and check for wear over time because heat is another big limit on speed-torque. If you spin a ball screw too fast, the recirculating ball bearings start to generate more friction and heat, which can cause the lubricant to break down, expand the metal parts, and lead to premature failure. That’s why every module has a maximum operating speed, and that speed is tied to the torque it can deliver at that point.
Let’s put this into a real-world example. A customer of ours makes custom lab automation equipment that moves tiny microplates with 96 wells each. Their application needs to move the plate between stations at 0.8m/s, and the total payload (plate plus fixtures) is only 2kg. We recommended our smallest, light-duty ball screw module with a 15mm diameter screw and a 10mm lead. At 3,200 RPM (the motor’s output), that gives a linear speed of 0.32m/s? No, wait, let’s do the math: RPM times lead divided by 60, so 3200 RPM x 10mm/RPM = 32,000 mm per minute, which is 0.53m/s. Wait, our actual module for light loads can spin the screw at up to 8,000 RPM, so with a 10mm lead, that’s 1.33m/s — perfect for their need. And since the load is only 2kg, the torque required is minimal, so the small screw can handle it without overheating or wearing out. If we’d given them a high-lead screw (20mm), they could hit 2.66m/s, but that would require more torque, and even though their load is light, the higher lead would mean the motor has to work harder to get that speed, and the system would vibrate more. For their delicate microplates, vibration is a no-go, so we stuck with the 10mm lead, which hits their speed target and keeps motion smooth.
On the other end of the spectrum, we had a customer in construction materials handling that needed to move 500kg pallets of stone blocks at 0.5m/s. They came to us thinking they needed a module that could move at 2m/s, but when we ran the numbers, their application only required 0.5m/s. If we’d given them a module sized for 2m/s, it would be overkill — more expensive, heavier, and not as rigid for their heavy loads. Instead, we paired a 30mm diameter ball screw with a 5mm lead. That lower lead means we can generate enough torque to move 500kg at 0.5m/s without stressing the system, and the larger screw handles the heavy load without deflection. If they tried to go faster, though, they’d need a different module — the torque curve for that 30mm screw drops off sharply at speeds above 1m/s, because the screw can’t spin fast enough without generating too much heat.
A common misconception is that higher speed is always better. But when you’re pushing heavy loads, speed often takes a backseat to torque and rigidity. And when you’re moving delicate parts, even if you can go fast, you might not want to — vibration from high-speed operation can ruin parts, cause positioning errors, or damage the module over time. That’s why the speed-torque characteristic isn’t just a spec on a datasheet — it’s a balance between your application’s needs, the module’s design, and long-term reliability.
As a supplier, we don’t just sell a box with a ball screw and a carriage. We work with customers to map their specific speed and torque requirements, factor in their load, acceleration, duty cycle, and even their environment (dust, temperature extremes, etc.) to pick the right module. For example, if a customer is using their module 24/7, 365 days a year, we might spec a slightly larger screw to handle the continuous torque load, even if it means a lower maximum speed, to prevent overheating. If they only need short, fast bursts of motion, we can size a module for peak torque instead of continuous, saving them money on parts that don’t get used.
Another thing to consider is efficiency. Ball screw modules are around 90% efficient, which is way higher than lead screws (around 30-50%), but that efficiency is tied to the speed-torque curve. At low speeds and high loads, efficiency drops a bit, because the balls have to work harder to move the load. At high speeds and low loads, efficiency is also high, because the balls are moving freely with minimal friction. That efficiency matters because it affects your energy costs, and also the motor size you need to pair with the module. If the module is inefficient at your operating speed, you’ll need a bigger motor, which adds cost and takes up more space.
Wear and tear is the final piece of the puzzle. The speed-torque curve directly impacts how long a ball screw module lasts. Operating outside the curve — for example, trying to move a heavy load at too high a speed — causes excessive friction, heat, and stress on the ball bearings and screw threads. Over time, this leads to pitting, wear, and play in the module, which ruins positioning accuracy and requires replacement. We test all our modules to ensure they operate within their speed-torque limits, and we provide clear guidelines on maximum speed, maximum load, and acceleration to help customers avoid costly mistakes.
If you’re evaluating a ball screw linear module for your application, don’t just look at the maximum speed or maximum load number. Dig into the speed-torque curve — ask your supplier what the continuous torque is at your operating speed, what the peak torque is for short bursts, and how the module performs under your exact load and acceleration. A good supplier will walk you through that, not just hand you a datasheet.
At the end of the day, the speed-torque characteristic of a ball screw linear module is all about matching the technology to your unique needs. Whether you’re moving tiny lab samples or heavy industrial parts, getting this balance right ensures your system is fast enough, strong enough, reliable enough, and cost-effective enough to keep your operations running smoothly.
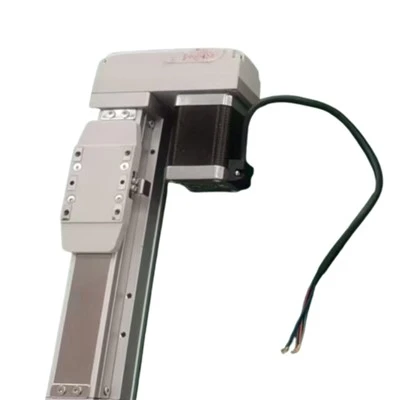
If you’re ready to talk through your specific application and find the right ball screw linear module for your needs, we’re here to help. Reach out to our team to discuss your project, review requirements, and get tailored recommendations that fit your budget and performance goals.
Riveting Equipment References
- Bolton, W. (2018). Mechatronics: Electronic Control Systems in Mechanical and Electrical Engineering. Pearson Education Limited.
- Krishna, V. G. (2020). Linear Motion Systems: Design, Analysis, and Applications. CRC Press.
- Shigley, J. E., & Mischke, C. R. (2004). Standard Handbook of Machine Design (3rd ed.). McGraw-Hill Education.
Yangning (Xiamen) Intelligent Technology Co., Ltd.
With abundant experience, we are one of the most professional ball screw linear modules manufacturers in China. As we have world-leading production equipment and strong manufacturing capabilities, we warmly welcome you to buy bulk advanced ball screw linear modules from our factory. Customized orders are welcome.
Address: Room 307-2, No. 15 Duiying Road, Software Park Phase III, Torch Hi-Tech Zone, Xiamen, Fujian, China
E-mail: mia@ynautos.com
WebSite: https://www.ynautos.com/
